
AgroBots: Bridging the Gap Between Multi-Agent Theory and Robotics in the Field
Applying AI to Cooperating Agricultural Robots
This paper introduces a Multi-Agent System (MAS) framework for cooperating agricultural robots using the Agent-Group-Role (AGR) model and the VOWELS paradigm. It specifically enables heterogeneous robots—explorers and transporters—to collaborate autonomously while allowing human intervention through dynamic role and plan management.
TL;DR
This research tackles the rigid nature of current agricultural robotics by applying core Multi-Agent System (MAS) principles. By using the Agent-Group-Role (AGR) model and the VOWELS paradigm, the authors created a system where robots can dynamically change "roles" (e.g., from mapping to spraying) and humans can intervene in real-time to adjust robot logic.
Problem & Motivation: The Rigidity of the Field
Agriculture is inherently unpredictable. A robot might start the day mapping weeds but need to switch to a pesticide-spraying tool by noon. Conventional systems struggle with two main "pains":
- Tool Changing: A physical tool change isn't just hardware; it requires a complete shift in how the robot interacts with its peers.
- Human Intervention: Farmers are experts who won't trust a "black box" system. They need a way to override autonomous decisions without shutting the whole system down.
The authors' insight? Treat the farm as a social organization where robots are agents with specific roles, rather than just pre-programmed machines.
Methodology: Organization-Centered MAS
The core of the solution lies in two theoretical frameworks:
1. The AGR Model (Agent-Group-Role)
Instead of hard-coding robot behaviors, the authors define:
- Roles: Responsibilities like "Explorer" or "Transporter."
- Groups: Contextual boundaries (e.g., "Field A Collaboration Group").
- Links: Communication channels restricted to group members.
This allows a robot to change its tool and simply "adopt a new role" within the organization, automatically updating its communication links and obligations.
2. The VOWELS Paradigm ()
Most MAS research ignores the User (U). By adopting the VOWELS paradigm, the user is treated as a specialized agent who can peer into the "BDI" (Belief-Desire-Intention) architecture of any robot to swap out its internal plans.
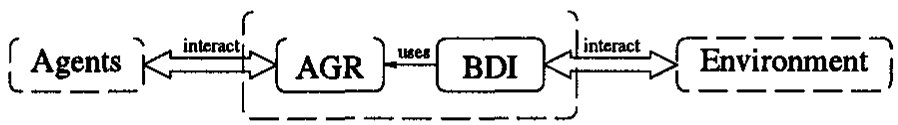 Figure 1: The extended agent architecture integrating BDI and the VOWELS paradigm for human control.
Implementation & Experiments
The researchers tested their approach using a "simulation-to-reality" pipeline:
- SoftBOT: Virtual agents for rapid strategy testing.
- LEGOBOT: Physical lab-scale robots to test sensor noise and movement.
- AgroBOT: Full-scale agricultural prototypes.
They developed Interaction Agents (IA) that allow a user to click on a robot in a GUI and literally "drag and drop" new plans or deactivate faulty roles.
 Figure 2: The transition from digital overview (a) to physical field implementation (b).
Critical Analysis & Conclusion
The value of this work is its pragmatism. While many MAS papers stay in the realm of pure math, this work proves that organizational theory can solve the messy problem of hardware modularity in agriculture.
Key Takeaways:
- Dynamic Role Swapping: The "Tool Changing" problem is effectively a "Role Change" problem in MAS.
- Transparent Autonomy: By exposing the BDI state to the user, the system earns the trust of the human operator.
Limitations: The paper focuses on the architecture rather than high-level coordination scaling (e.g., what happens with 100 robots?). Future work must address how human intervention scales when managing large swarms across vast estates.
The convergence of Pervasive Computing and MAS shown here suggests a future where robots are not just tools, but flexible team members in a human-centric digital ecosystem.