
Optimal Control for Manufacturing: Balancing Lot-Sizing and Timing
17836_Optimal control laws for lot-sizing and timing of jobs on a single production facility.
This paper presents a discrete-event dynamic system model for the optimal control of a single production facility. It addresses the joint optimization of job lot-sizing and timing (sequencing being fixed) using a multistage optimal control framework and Dynamic Programming to minimize quadratic deviations from production targets.
TL;DR
This research tackles the challenge of controlling a single machine by simultaneously deciding when to process a job and how many items it should contain. By modeling the factory as a discrete-event system, the authors provide a mathematical way to minimize delivery delays and production deviations, introducing a "busy block" strategy that simplifies complex industrial schedules into manageable pieces.
Background: The Gap Between Planning and Execution
In industrial engineering, there is often a divorce between the planning level (Materials Requirement Planning) and the execution level (Scheduling). Planning typically uses continuous-time models, while scheduling lives in a discrete-event world. The authors argue that to truly optimize production, we must integrate these levels by treating timing and lot-sizes as coupled control variables.
The Mathematical Intuition: Multistage Control
The machine's state is defined by the completion time of a job . The control variables are:
- Job execution speeds ()
- Lot sizes ()
- Idle times () between jobs.
The cost function is a "weighted quadratic penalty" for any deviation from the ideal: being too early or too late (Earliness/Tardiness), or producing more/less than the target lot size.
1. The Busy Block Concept
One of the most powerful insights in the paper is the Decoupling Condition. If the machine is ever idle (), the future of the schedule becomes independent of the past. The authors call a sequence of jobs with zero idle time a "Busy Block."
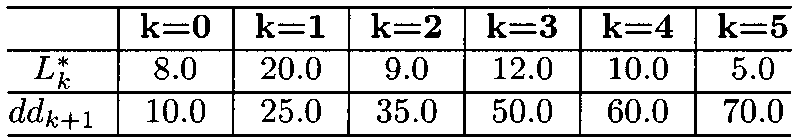 Table showing nominal lot sizes () and due dates ()
Methodology: From Kuhn-Tucker to Dynamic Programming
For the general case, the authors apply Kuhn-Tucker conditions to find the necessary requirements for an optimal path. However, for a simplified version (fixed machine speed), they use Dynamic Programming (DP).
The DP approach yields a closed-loop law: the optimal lot size is a linear function of the current completion time . This means the controller can react instantly to current state changes.
Results and Real-Time Control
A static schedule is useless the moment a machine breaks down or a part arrives late. The authors propose a Real-Time Control Scheme that monitors the "Busy Block" structure.
- Case 1 (Minor Disturbance): If a job is delayed but doesn't change which jobs are "clumped together" in a busy block, the existing linear control laws are still optimal.
- Case 2 (Major Disturbance): If the delay is so large that it merges two busy blocks or alters the fundamental timing, the system re-runs the quadratic program to find a new structure.
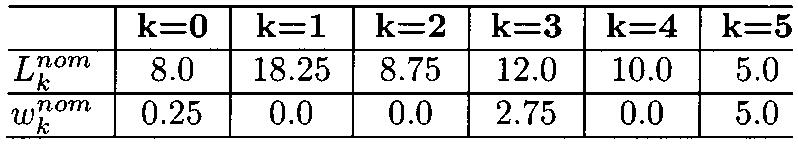 Optimal lot sizes () and idle times () calculated for a 6-job sequence.
Critical Insight & Conclusion
This work demonstrates that manufacturing "scheduling" doesn't have to be a rigid, one-off plan. By viewing it through the lens of Optimal Control Theory, it becomes a dynamic, feedback-driven process.
Limitations: The sequence of jobs is still "fixed" in this study. In real-world scenarios, the order of jobs is often as important as the lot size. The authors conclude that further research is needed to combine sequencing (which job goes first) with this timing and sizing framework, likely moving into the realm of Mixed Integer Programming.